Loading & Unloading Systems
VECTIS
Rail-Mounted Slab Loading and Unloading Robot
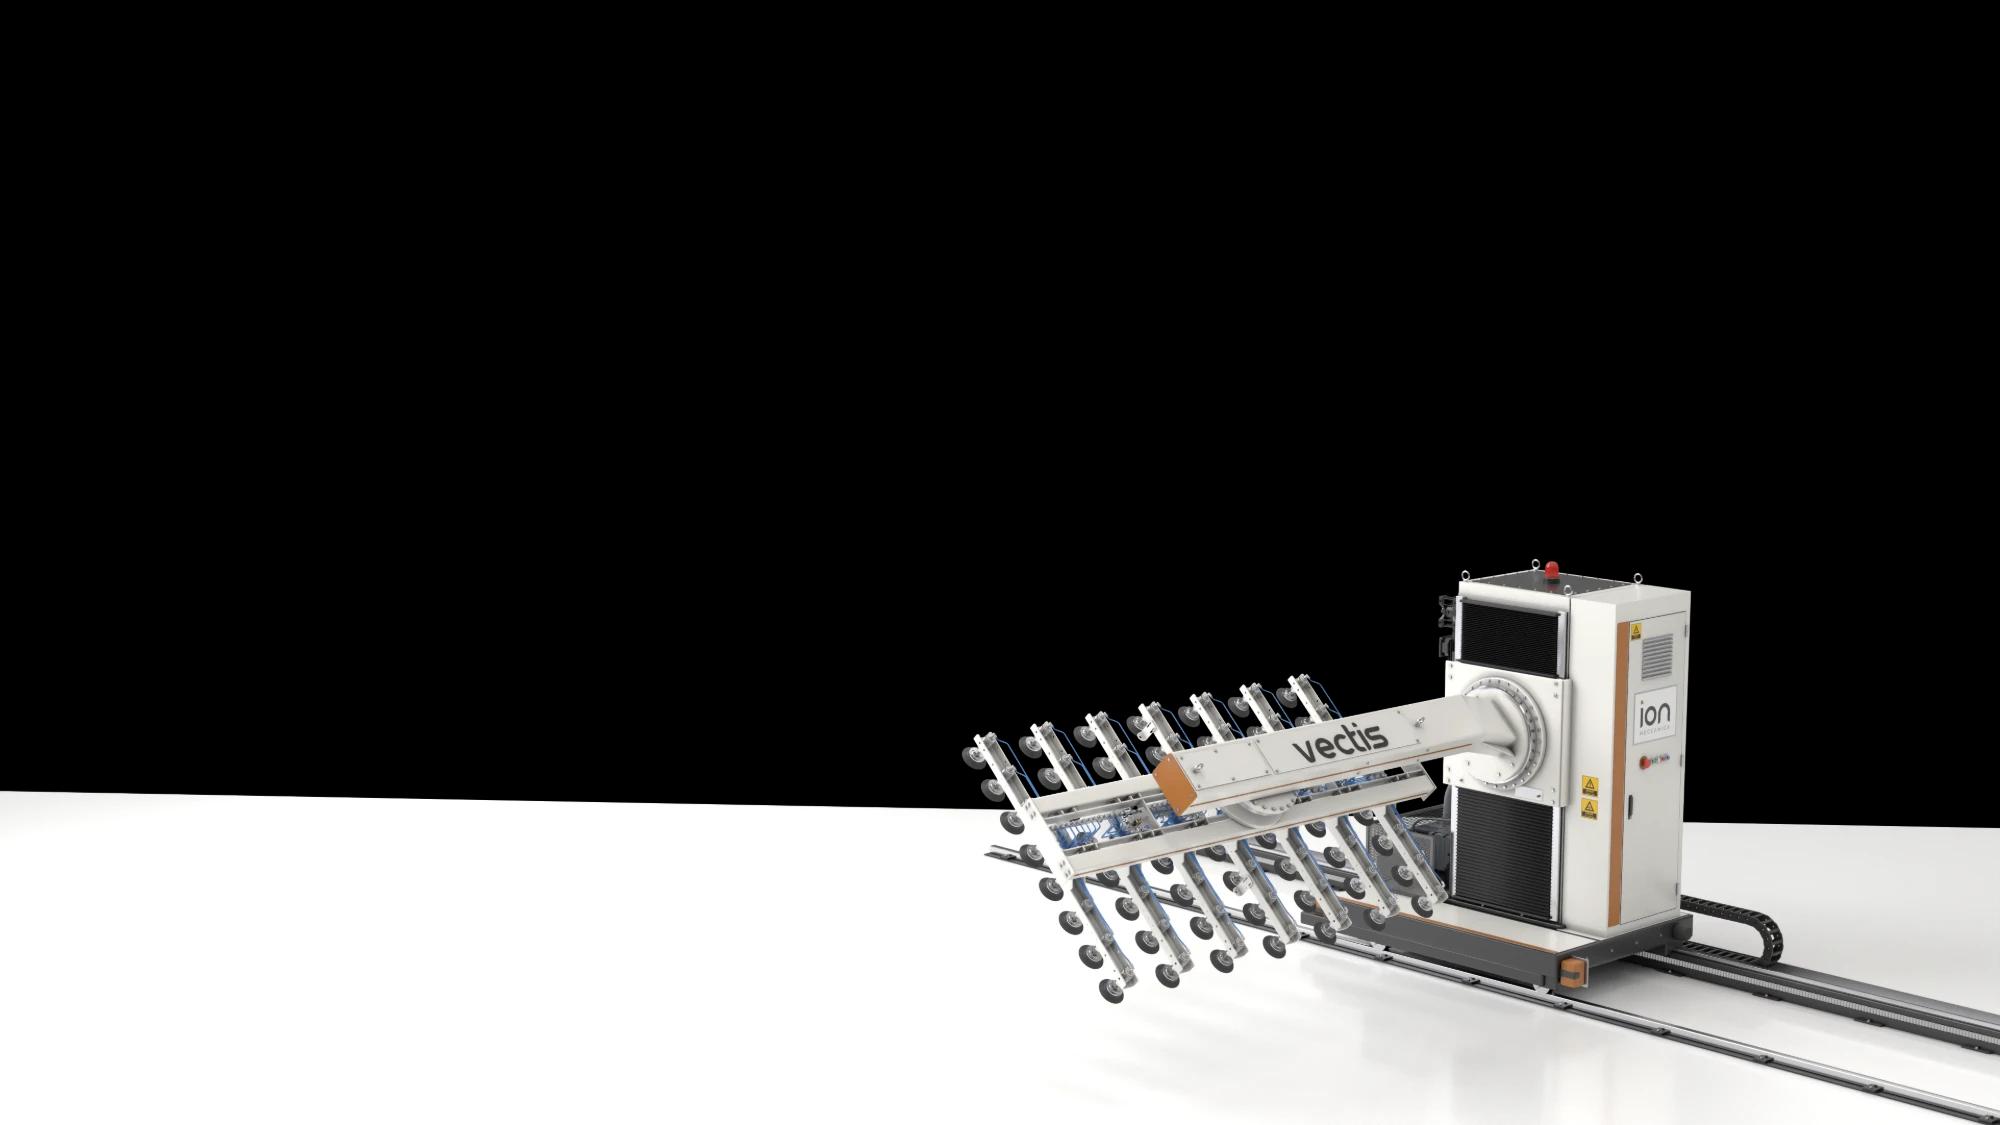
VECTIS is a single-column, rail-mounted robotic system designed for the automatic loading, unloading and transfer of marble, granite and other natural-stone slabs. Its compact structure and configurable vacuum comb provide flexible handling solutions for polishing lines, resin-treatment systems and other automated stone-processing operations.
Description & Technical Details
VECTIS is a floor-mounted robotic handling system developed for the automatic transfer and positioning of natural-stone slabs within industrial processing lines.
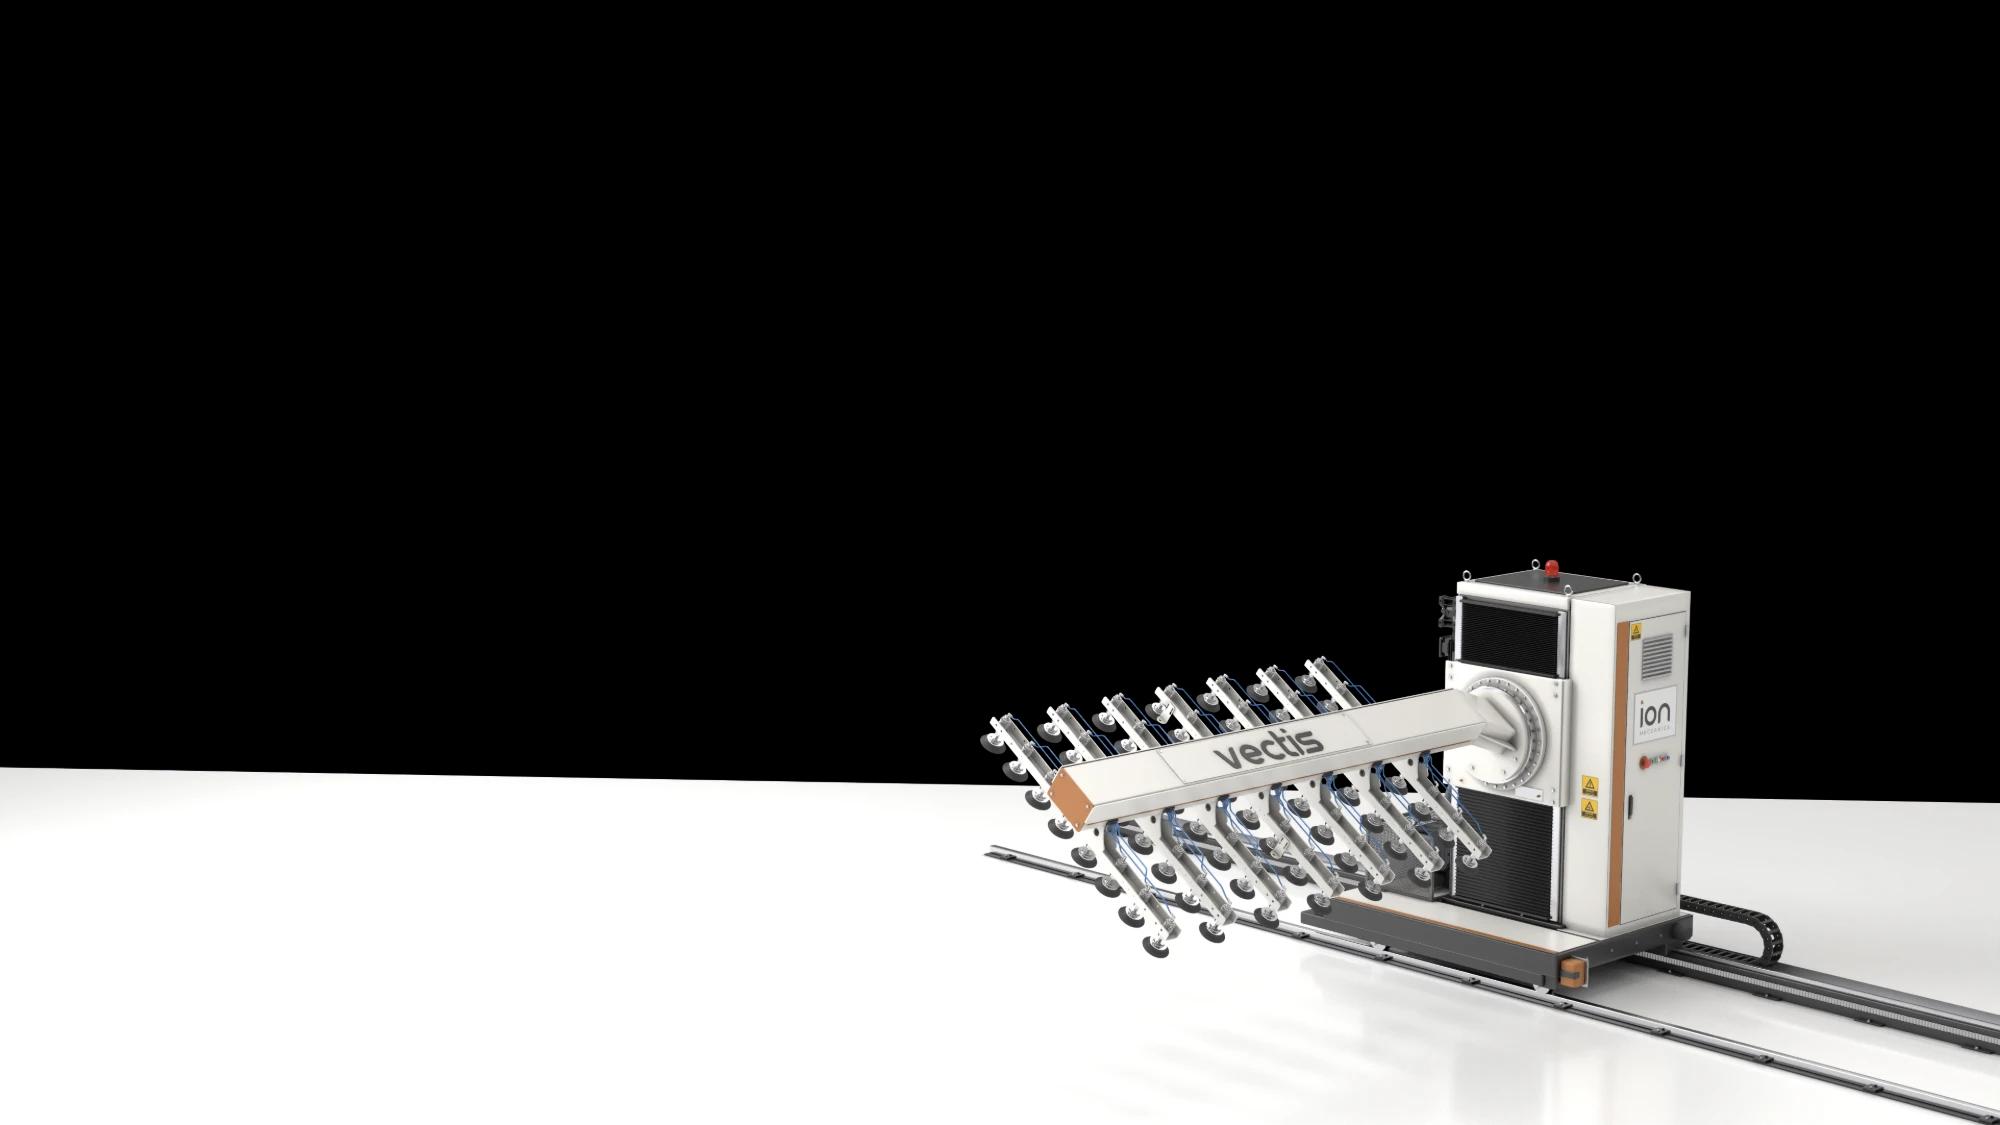
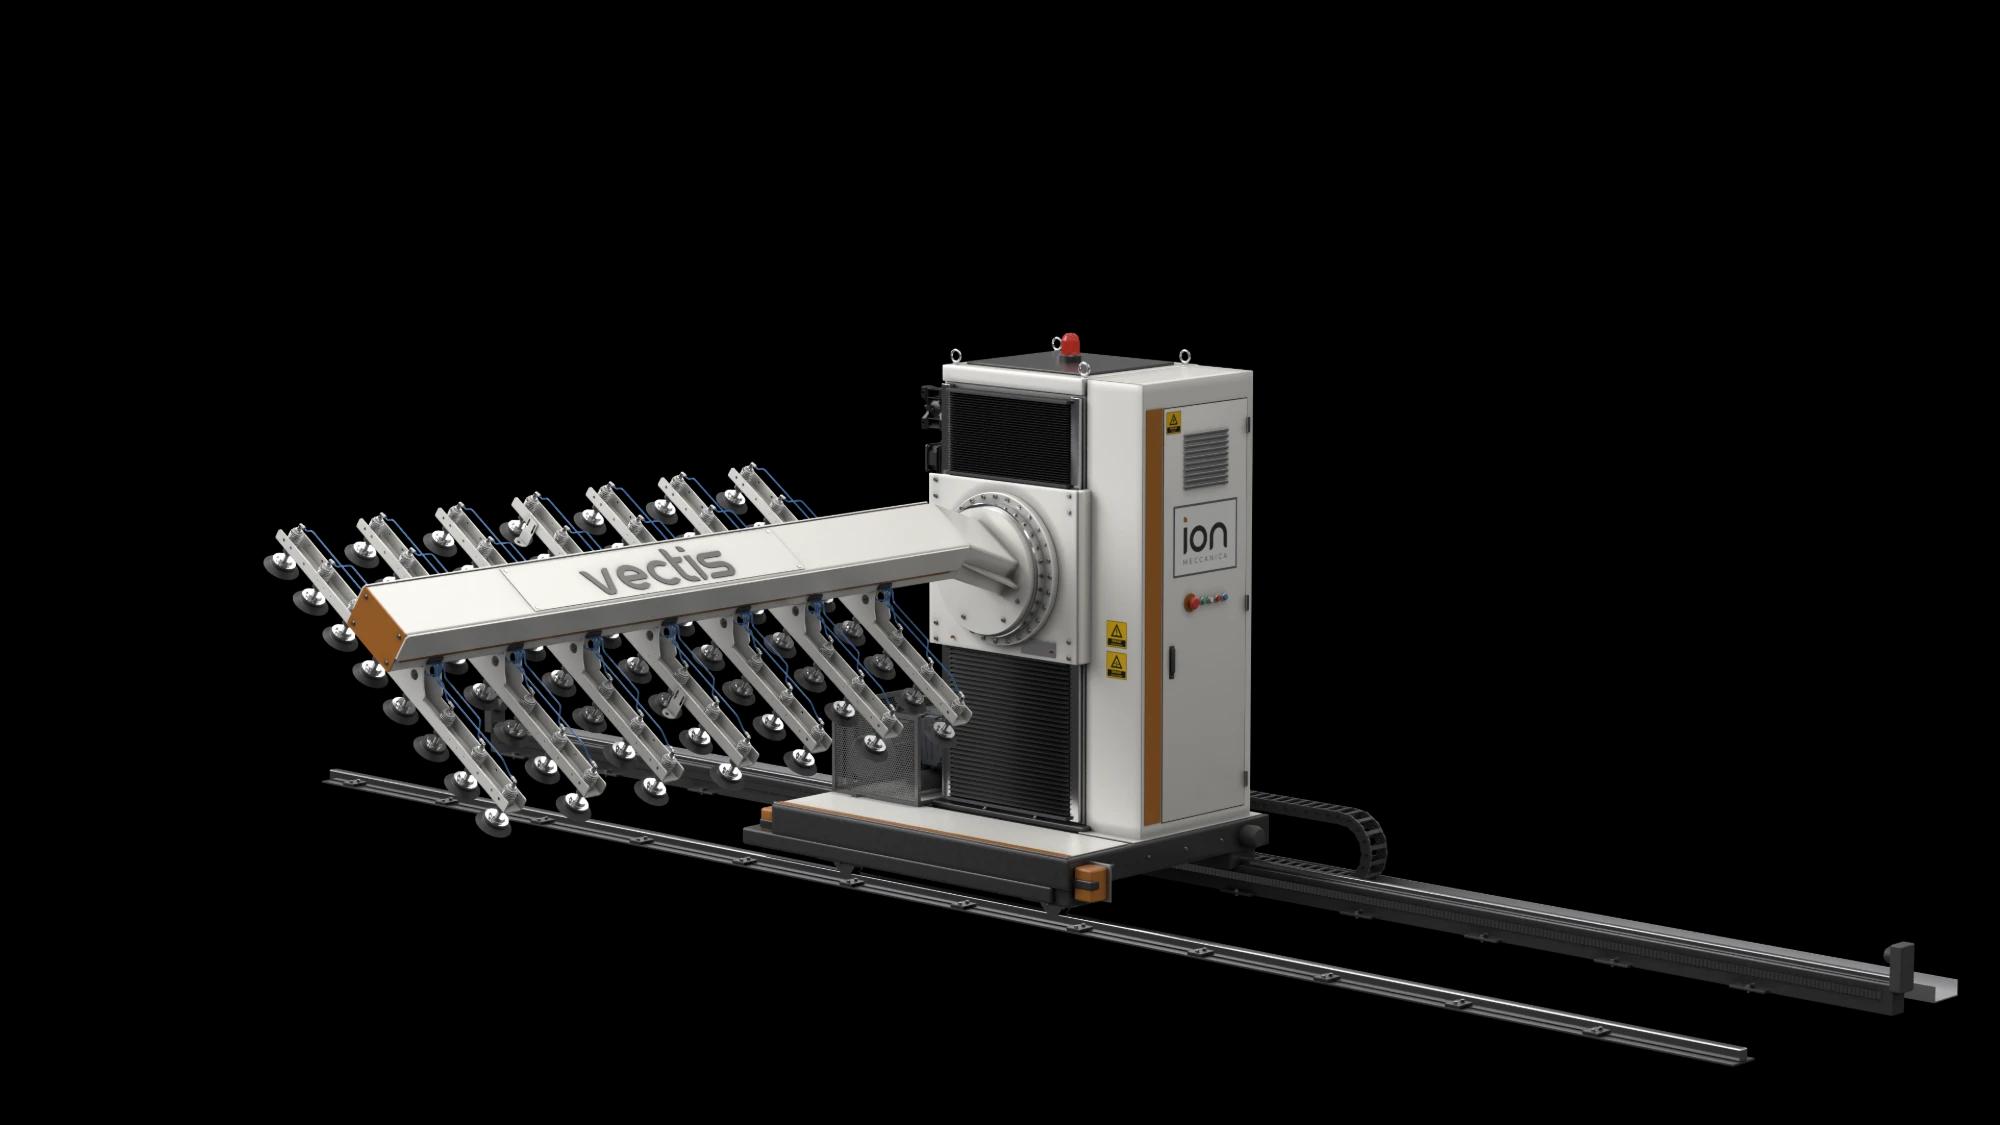
The machine combines a rigid vertical column, a motorised rail-travelling carriage and a cantilevered vacuum lifting comb. This arrangement allows slabs to be picked up, transferred and positioned between processing stations while maintaining controlled movement throughout the handling cycle.
The vacuum comb consists of seven arms equipped with multiple suction cups distributed across the slab contact area. The standard configuration incorporates 56 suction cups, arranged as eight cups per arm. Alternative configurations with 28 or 70 suction cups are available to accommodate different stone characteristics and handling requirements.
The machine is designed for slabs up to 3,600 × 2,200 mm, with the final handling capacity determined by slab weight, material characteristics and the selected vacuum configuration.
VECTIS is available in two versions: VECTIS S, with a fixed vacuum comb, and VECTIS R, incorporating a powered rotating comb arm for additional slab-handling flexibility. Both versions share the same fundamental single-column architecture.
The robotic system is designed for integration with automated polishing lines, resin-treatment systems and other slab-processing equipment. Its modular construction allows the vacuum comb, rail travel and operating sequence to be configured according to the production-line layout.
VECTIS S – Standard
VECTIS S is equipped with a fixed vacuum comb and is developed for automatic slab loading, unloading and transfer operations.
The robot travels along floor-mounted rails, while the vertical movement system positions the vacuum comb at the required pickup and unloading heights.
Its mechanically simpler arrangement is particularly suitable for applications where the required slab-handling sequence does not involve additional comb rotation.
VECTIS S can be integrated with polishing machines, slab conveyors, resin-treatment lines and other automated handling stations.
VECTIS R – Rotating
VECTIS R incorporates an additional powered rotation mechanism in the vacuum comb assembly, providing greater flexibility in slab orientation and handling.
The rotating comb allows the robot to perform controlled turning movements during slab transfer, making it suitable for applications requiring changes in slab orientation, including bookmatch and slab-face reversal operations where supported by the complete installation.
The movement sequence can be coordinated with the surrounding production equipment, allowing slab transfer and turning operations to be incorporated into the automatic production cycle.
VECTIS R retains the same rail-mounted, single-column structure and vacuum-comb configuration options as VECTIS S.
VECTIS 28 – Large-Cup Configuration
Equipped with seven comb arms, each carrying four suction cups, for a total of 28 suction cups, especially suitable for polishing machines and workshop machines. This configuration uses larger suction cups to provide gripping contact through fewer vacuum points. It is intended for slabs with suitable surface characteristics and structural integrity, while reducing the number of vacuum components installed on the comb.
VECTIS 56 – Standard Configuration
Equipped with seven comb arms, each carrying eight suction cups, for a total of 56 suction cups. This is the standard VECTIS vacuum configuration, designed to provide a balanced distribution of gripping points across the slab surface for general marble and granite handling applications.
VECTIS 70 – High-Density Configuration
Equipped with seven comb arms, each carrying ten suction cups, for a total of 70 suction cups. The increased number of contact points provides a more distributed gripping arrangement, particularly relevant when handling slabs with fissures, variable material strength or other characteristics requiring additional support across the stone surface. The suction-cup diameter, vacuum capacity and operating parameters are selected according to the configuration and application requirements.
All three vacuum configurations are available for both VECTIS S and VECTIS R.
• Single-column, floor-mounted robotic structure
• Motorised horizontal travel on floor-mounted rails
• Controlled vertical slab lifting and positioning
• Maximum slab dimensions: 3,600 × 2,200 mm
• Automatic slab loading, unloading and transfer
• Configurable vacuum gripping arrangement
• Adaptable rail length and installation layout
• Designed for PLC-based automatic control and line integration
• Integration with polishing, resin-treatment lines and workshop machines
• Bookmatch and slab-turning applications with VECTIS R, subject to installation configuration
Extended Rail System
The floor-mounted rail system can be adapted according to the required distance between loading, unloading and processing stations.
Custom Vacuum Comb
The suction-cup diameter, spacing and arrangement can be adapted to the characteristics of the stone and the requirements of the production process.
Fragile Stone Handling
Additional vacuum distribution and mechanical support arrangements can be developed for slabs with cracks, fissures or reduced structural integrity.
Production Line Integration
VECTIS can be configured for communication and coordinated operation with polishing lines, resin-treatment equipment, slab conveyors and automated transfer systems.
Photos & Videos
Planning a project with VECTIS?
Share your material, slab size and capacity target, and we will prepare the right configuration and quotation for you. Technical data sheets are available on request.